In the ever-evolving world of robotics, an intriguing development has emerged from China, challenging the traditional notion of robot intelligence. Feagine Robotics, a pioneer in this field, has introduced Fi0, a groundbreaking foundation model that defies the norm. Unlike most robot AI systems, Fi0 is designed with a unique ability: it can retain task knowledge across robots with varying physical structures. This innovation addresses a critical issue in robotics, where changing a robot's body often requires a significant overhaul of its intelligence.
The Body as a Challenge
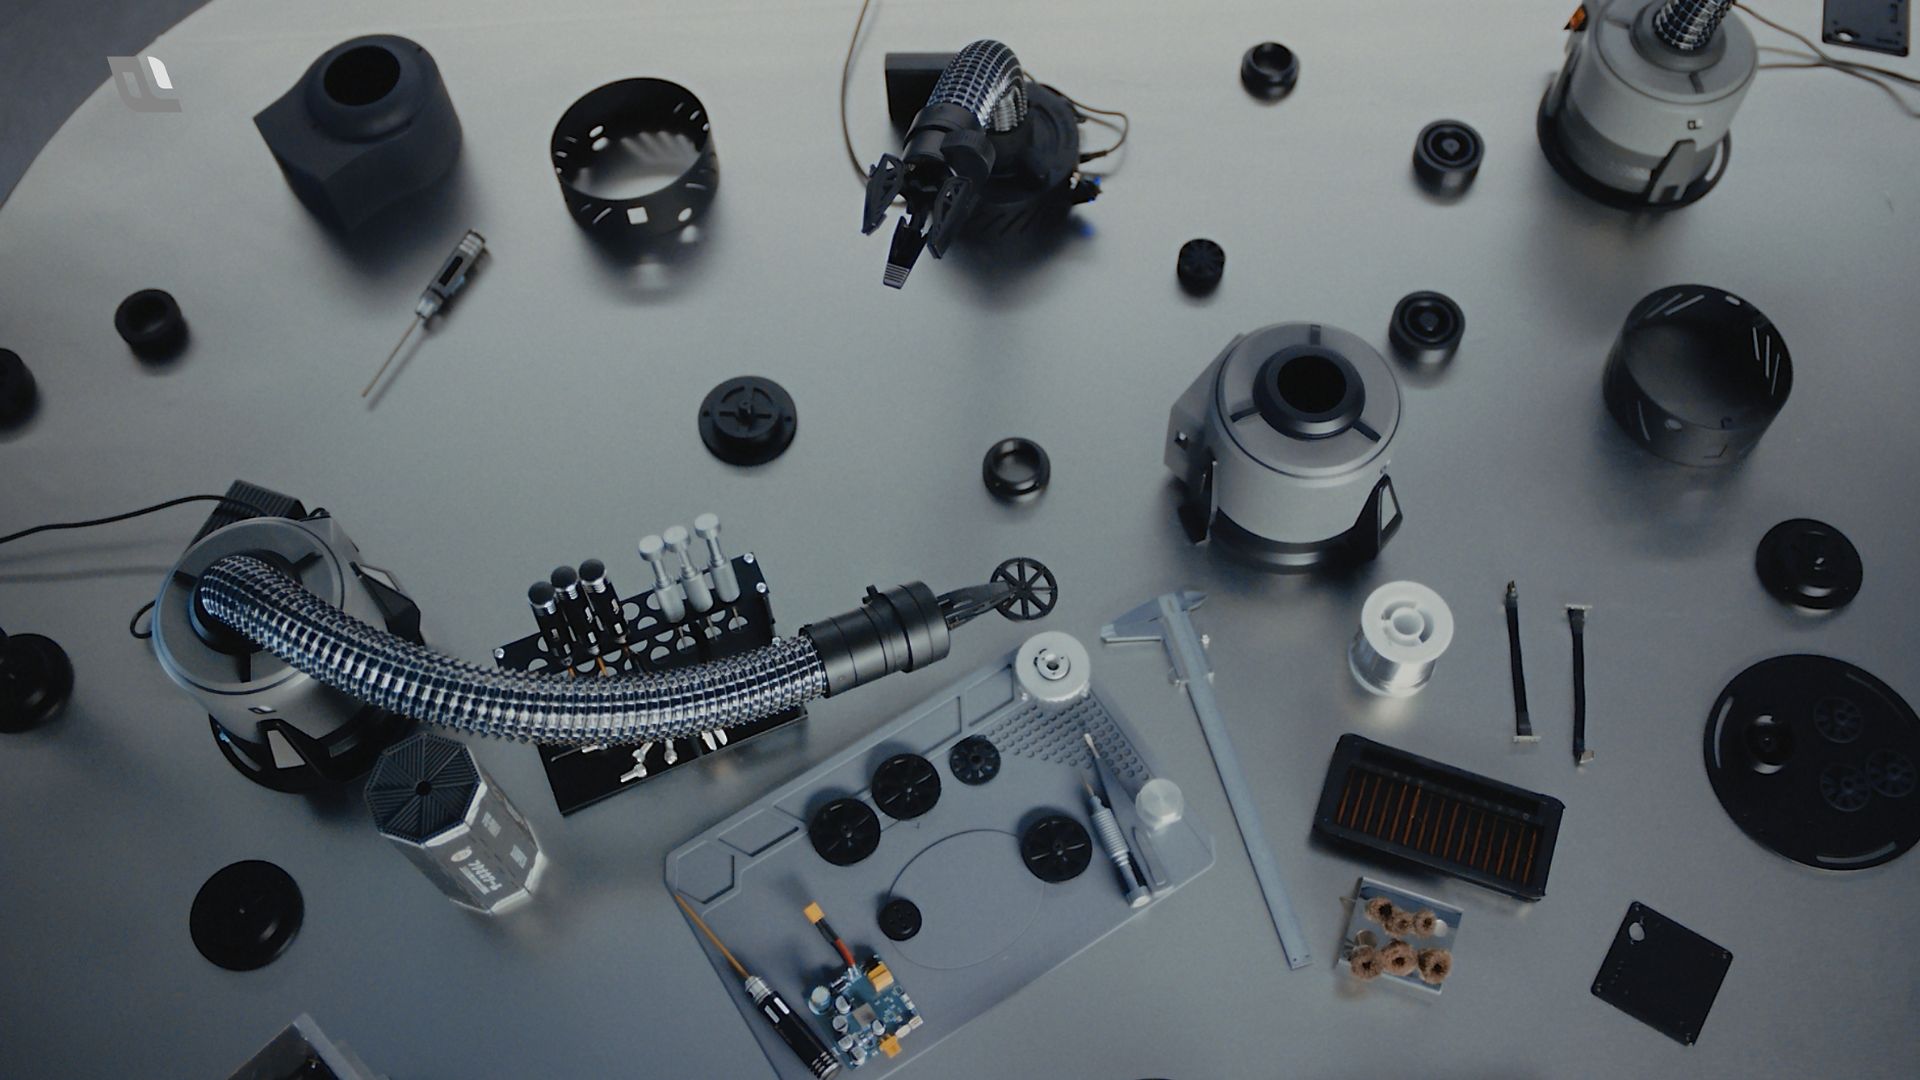
A robot's physical structure is more than just a shell; it determines its capabilities. An arm with two segments has a different reach than one with three, and a soft, bending arm adds a layer of complexity with its shape-shifting nature. Feagine's trio of manipulators, A01, A02, and A03, are designed to showcase this diversity. Each manipulator has unique characteristics, from segment counts to payload capacities, providing a systematic exploration of these differences.
Cross-Embodiment Intelligence
Fi0 represents a paradigm shift with its 'cross-embodiment' approach. It treats the robot's physical structure and current state as integral parts of the information used to generate actions. This means that the task remains consistent, even when the physical method of execution changes. It's a concept that Feagine demonstrates through a single task, showcasing how Fi0 can adapt and learn across different robots.
Beyond Retraining
One of the most intriguing aspects of Fi0 is its ability to reduce the need for extensive retraining. When faced with an unfamiliar task, a human demonstration is all it needs. Instead of a lengthy training cycle, Fi0 uses this demonstration as context, extracting essential information like objects, sequences, and desired outcomes. The robot then figures out how to execute the task with its unique body. This approach aligns with a broader trend in robotics research, where foundation models are sharing knowledge across different robot embodiments, moving away from isolated learning for each machine.
The Soft Robot Advantage
Feagine's choice to use soft, tendon-driven manipulators is deliberate. Traditional robotic arms are straightforward mechanically, with defined joint positions and movements. Soft manipulators, on the other hand, are continuously bending, shape-shifting, and compliant with their surroundings. This complexity makes the robot's physical configuration a critical part of the AI's understanding. Fi0's architecture incorporates information about the robot's morphology, sensing, actuation, and current state, creating an 'Embodiment Graph.' This graph, along with components for environmental understanding and action prediction, forms the basis of Feagine's 'soft embodied intelligence.'
A New Vision for Robotics
The implications of Feagine's work are far-reaching. It suggests that the future of robotics may not be a single universal machine but a diverse family of specialized robots, each with its own unique body, sharing an intelligent layer. This challenges the dominance of humanoid robots, which have gained attention due to their ability to navigate human-centric environments. However, general-purpose intelligence doesn't necessarily require a humanoid body. Feagine's approach asks a different question: can one intelligence operate many specialized bodies?
Conclusion
Fi0 is an exciting development, offering a potential solution to a critical bottleneck in embodied AI. While it's still in its early stages, the concept has the potential to revolutionize how we think about robotics. As Feagine continues to develop and test Fi0 across a broader range of hardware, tasks, and real-world environments, we may see a future where robots are not just specialized tools, but intelligent beings capable of adapting and learning across a diverse range of bodies.